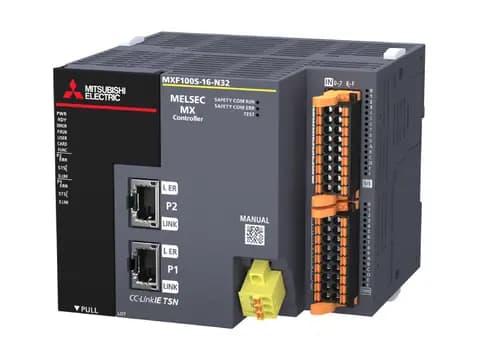
MXF100S-8-P32 - Program memory (standard): 30 MB Program memory (safety): 6 MB Maximum number of…
رقم القطعة: MXF100S-8-P32_7788
لا يعرض أي بائع سعرًا لهذا المنتج بعد.
للطلب والدفع استخدم تطبيق ENG.

رقم القطعة: MXF100S-8-P32_7788
لا يعرض أي بائع سعرًا لهذا المنتج بعد.
للطلب والدفع استخدم تطبيق ENG.
MXF100S-8-P32 - Program memory (standard): 30 MB Program memory (safety): 6 MB Maximum number of…
| Basic information / Model name | MXF100S-8-P32 |
|---|---|
| Basic information / Overview | Program memory (standard): 30 MB Program memory (safety): 6 MB Maximum number of controllable axes: 8 axes Built-in CC-Link IE TSN (with Safety Functions) Input (standard): 16 points Output (standard): 16 points transistor (source) |
| Basic information / Sales status | On sale |
| Listed / Model name | MXF100S-8-P32 |
| Basic information / Conformance standard | UL cUL CE(EMC) CE(RoHS) CE(Machinery) KC(EMC) |
| Operating atmosphere | No corrosive gases and flammable gases, less conductive dust |
| Installation location | Inside a control panel*10 |
| Grounding | Grounding resistance of 100Ω or less (Common grounding with a heavy electrical system is not allowed)*8 |
| Inrush current | 100 A, 0.06 ms or less 4.0 A, 350 ms or less |
| Noise immunity | By noise simulator at noise voltage of 1000 Vp-p, noise width of 1 μs and period of 30…100 Hz |
| Storage ambient temperature | -40…75°C, non-freezing*4 |
| Operating ambient humidity | 5…95% RH, non-condensing*5 |
| Storage ambient humidity | 5…95% RH, non-condensing |
| Overvoltage category*11 | II or less |
| Pollution degree*12 | 2 or less |
| Operation control method | Repetitive operation of stored programs |
| I/O control mode | Refresh mode (The direct access input/output is available by specifying the direct access input/output (DX, DY).) |
| Programming language | • Ladder diagram (LD) • Structured text (ST) • Function block diagram (FBD/LD) |
| Extended programming language | • Function block (FB) • Label programming |
| Program execution type | Initial, scan, fixed scan, interrupt, and standby |
| Number of I/O points | 512 points |
| Memory capacity / Program memory | • Standard: 30 MB • Safety: 6 MB |
| Memory capacity / Program cache memory | • Standard: 12 MB • Safety: 2 MB |
| Memory capacity / Device/label memory | • Standard: 8192 KB • Safety: 80 KB |
| Memory capacity / Data memory | 15 MB |
| Online change | Supported (standard program only) |
| Processing speed / Instruction processing time / LD instruction | • Standard control: 1.25 ns • Safety control: 124 ns |
| Number of occupied I/O points | Not supported |
| Number of slots occupied by a module | Not supported |
| USB port | USB 2.0 High Speed (Type-C) × 1 |
| Ethernet port | One of the CC-Link IE TSN ports can be switched to the Ethernet port. |
| CC-Link IE TSN port | 1000BASE-T/100BASE-TX × 2 One of the CC-Link IE TSN ports can be switched to the Ethernet port. |
| SD memory card | SD/SDHC memory card |
| Number of controllable axes / Real drive axis | 8 axes |
| Motion operation cycle [μs] | 250, 500, 1000, 1500, 2000, 2500, 3000, 3500, 4000, 4500, 5000, 5500, 6000, 6500, 7000, 7500, 8000 |
| Servo amplifier connection | MR-J5-G, MR-J5W2-G, MR-J5W3-G, MR-J5D1-G4, MR-J5D2-G4, MR-J5D3-G4, CC-Link IE TSN-compatible drive, MR-JET |
| Absolute position control system | 64 bit control/32 bit control |
| Positioning range | 64 bit floating-point (LREAL type) |
| Interpolation function | Linear interpolation (4 axes maximum), 2-axis circular interpolation |
| Control method | PTP control, speed control, speed-position switching control (future support), speed control/torque control/continuous operation to torque control, pressure control (future support), multi-axis positioning data operation, position follow-up control, and motion cyclic instruction (position, velocity, and torque) |
| Operation cycles mixed | 3 groups |
| System memory size | 96 MB |
| Size of built-in ROM for user data | 15 MB (Data memory is used.) |
| Axis | Real drive axis, virtual drive axis, real encoder axis, virtual encoder axis, and virtual linked axis |
| Axis / Axes group | 0: Not set 1…: Setting axes group No. |
| Axis / Real drive axis | Servo amplifier |
| Axis / Real encoder axis | Via a servo amplifier |
| Compensation function | Driver unit conversion function and phase compensation function (future support) |
| Synchronous control / Instruction | Advanced synchronous control and cam operation start (MC_Camln) |
| Synchronous control / Module | Master axis, cam, gear, and clutch |
| Synchronous control / Master axis | Real drive axis, virtual drive axis, real encoder axis, virtual encoder axis, and virtual linked axis |
| Start/stop | Start, stop, restart, buffer mode, and forced stop |
| Home position return / Home position return method | Driver home position return method (use the home position return method set in the driver) |
| Positional control / Linear control | Linear interpolation (2…4 axes) |
| Positional control / 2-axis circular interpolation | Border point specification, center point specification, and radius specification |
| Manual control | JOG operation |
| Direct control / Speed control | Speed control not including position loop and speed control including position loop |
| Direct control / Torque control | Torque control and continuous operation to torque control |
| Absolute positioning system | Provided (batteryless) |
| Function to limit control / Velocity limit | Velocity set range |
| Function to limit control / Torque limit | Positive direction torque limit value, negative direction torque limit value |
| Function to limit control / Forced stop | Enabled/disabled switching |
| Function to limit control / Software stroke limit | Check the movable range at the set position and the machine feed value. |
| Function to limit control / Hardware stroke limit | Supported |
| Function to change control content / Set velocity change | Supported |
| Function to change control content / Current value change | Supported |
| Function to change control content / Acceleration/deceleration process change | Acceleration/deceleration and acceleration/deceleration time |
| Function to change control content / Torque limit value change | Supported |
| Function to change control content / Target position change | Target position change and movement distance change |
| Function to change control content / Override | Supported |
| Function / History data | Position data history |
| Function / Axis emulation | Supported |
| Function / Touch probe (mark detection) | Supported |
| Function / Monitoring of servo data | Cyclic transmission and transient transmission |
| Function / Servo system recorder | Not supported |
| Function / Digital cam switch | Supported |
| Number of registrations | 60000 maximum (settable number from engineering tool: 1024) |
| Cam data / Type | Cam data and rotary knife |
| Cam data / Interpolation method | Specifying for each section, linear interpolation, and spline interpolation |
| Cam data / Profile ID | 1…60000 |
| Cam data / Resolution | 8…65535 (optional) |
| Cam data / Unit of length per cycle setting | mm, inch, pulse, degree |
| Cam data / Unit of stroke amount | %, mm, inch, pulse, degree |
| Cam auto-generation | Cam auto-generation cam for rotary knife |
| Transmission speed | 1 Gbps/100 Mbps |
| Maximum number of connectable stations per network | 39 stations (manager station: 1, device station: 38) |
| Network topology | Line topology, star topology, coexistence of line and star topologies |
| Overall cable length / Line connection | 3800 m (when 39 stations are connected) |
| Overall cable length / Others | Depends on the system configuration. |
| Maximum station-to-station distance | 100 m |
| Maximum number of link points per network / RX/RY | 16K points (16384 points, 2 KB) for each |
| Maximum number of link points per network / RWr/RWw | 8K points (8192 points, 16 KB) for each |
| Maximum number of link points per station / RX/RY | Manager station: 8K points (8192 points, 1 KB) for each |
| Maximum number of link points per station / RWr/RWw | Manager station: 4K points (4096 points, 8 KB) for each |
| Connection cable | Ethernet cable (Category 5e or higher) |
| Communication method | Time sharing method |
| Transient transmission capacity | Maximum 1920 bytes |
| Listed / Outline | Program memory (standard): 30 MB Program memory (safety): 6 MB Maximum number of controllable axes: 8 axes Built-in CC-Link IE TSN (with Safety Functions) Input (standard): 16 points Output (standard): 16 points transistor (source) |
| Voltage fluctuation range | +20%, -15% |
| Power fuse | 125 V, 3.15 A time-lag fuse |
| Power consumption | Controller alone: 25 W or less Maximum configuration for connection to the controller: 45 W or less (external 24 V DC power supply of extension devices is not included) |
| 24 V DC built-in power supply capacity | 500 mA |
| 5 V DC built-in power supply capacity | 720 mA |
| Rated voltage*1 | 24 V DC |
| Allowable momentary power failure time*2 | - |
| Safety category | Category 4 (EN ISO 13849-1) |
| Performance level (PL) | PL e (EN ISO 13849-1) |
| Safety level (SIL) | SIL 3 (EN 61508) |
| Operating ambient temperature*3 | 0…55°C, non-freezing |
| Vibration resistance*6 / Installed on DIN rail / Frequency: 5…8.4 Hz | Half amplitude: 3.5 mm Number of sweeps: 10 times each in X, Y, and Z directions (total 80 minutes in each direction) |
| Vibration resistance*6 / Installed on DIN rail / Frequency: 8.4…150 Hz | Acceleration: 10 m/s2 Number of sweeps: 10 times each in X, Y, and Z directions (total 80 minutes in each direction) |
| Shock resistance*7 | 150 m/s2, Duration of action: 11 ms, 3 times each in X, Y, and Z bidirections by sine half-wave pulse |
| Operating altitude*9 | 0…2000 m |
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر
Mitsubishi Electric
اطلب عرض سعر